Window Shape Estimation for Glass Façade-Cleaning Robot
Window Shape Estimation for Glass Façade-Cleaning Robot
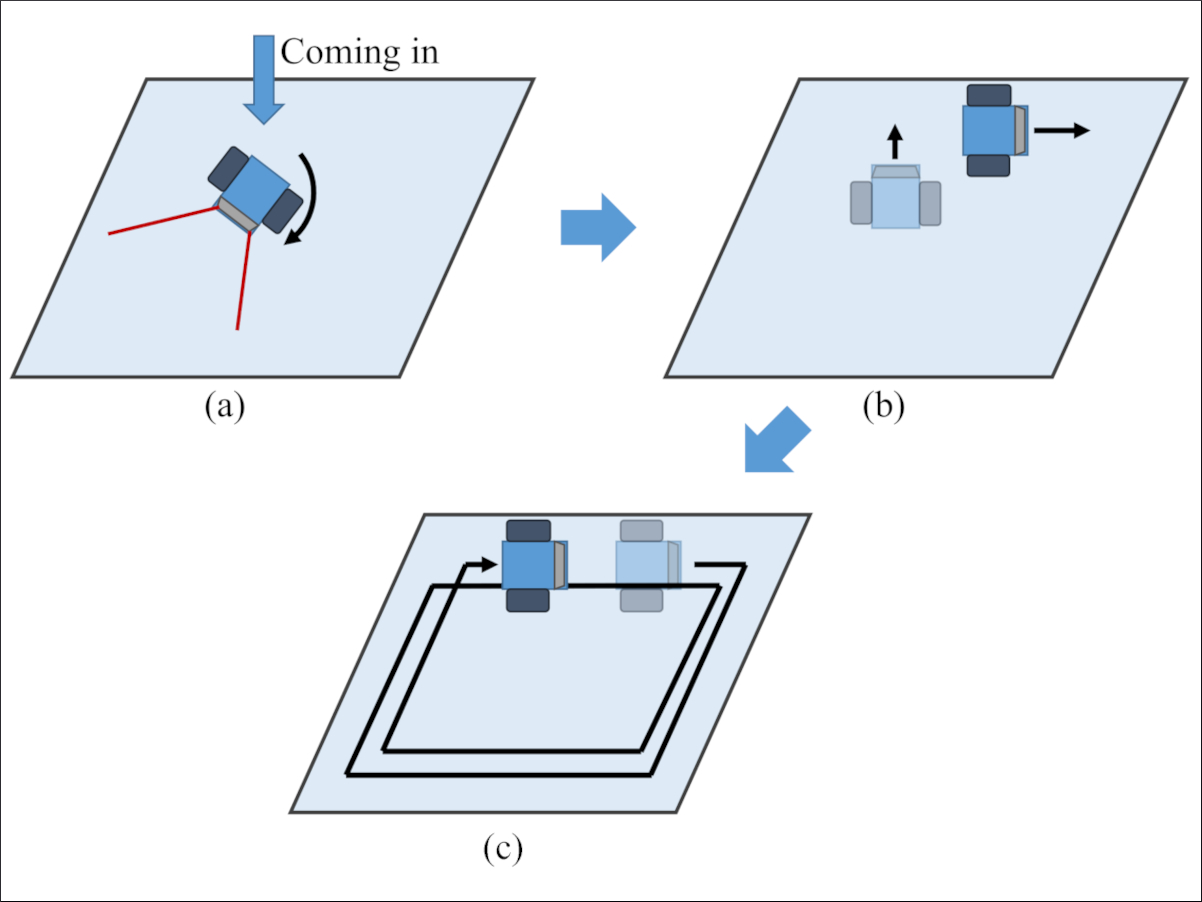
This paper presents an approach to the estimation of a window shape for increasing the adaptability of glass façade-cleaning robots to different buildings.
Related Keywords
Sasahira, Nagano, Japan, Shanghai, China, Germany, South Korea, Munich, Bayern, New York, United States, Republic Of Korea, Masami Iwase, Hiroshi Itoh, Takuma Nemoto, Shohei Iizuka, Shunsuke Nansai, Research Institute For Science, Technology Of Tokyo Denki University, Shanghai World Financial Center, World Trade Center, Special Issue Modeling, Sensor Fusion, Control Techniques, Applied Robotics, New York City, Nested Reconfigurable Robots, Window Scanning, Based Experimental, Research Institute, Tokyo Denki University, Glass Cleaning, Lass Facades, Robots, Windows Cleaning, Acades, Uilding Envelopes And Systems,